Choose based on the job, not the label: a conventional industrial robot is often the better fit for stable, high-speed production, while a collaborative robot (cobot) may suit work that benefits from people nearby or frequent task changes. But “robotic arm” and “traditional industrial robot” are not opposite categories: an articulated arm is one type of industrial robot, and a cobot can also be an arm.
What does “robotic arm vs. industrial robot” mean?
A robotic arm describes a machine form, not a separate category that excludes industrial robots. The International Federation of Robotics (IFR) defines an industrial robot using the ISO definition: an automatically controlled, reprogrammable multipurpose manipulator programmable in three or more axes. Articulated arms are among the industrial robot types; collaborative robots are another application category, and many are arms. See the IFR overview of industrial robot types and FANUC’s industrial robot overview.


For a factory decision, the useful comparison is usually a cobot application versus a conventional industrial robot installed in an engineered cell. Other industrial robot configurations may also be candidates. Compare each against the process and the complete system needed to run it.
Which is right for your factory?
A conventional industrial robot is a stronger candidate when high throughput, speed, demanding payloads or short cycle times are the priority and the process is stable enough to justify a dedicated cell. IFR says collaborative robots complement rather than replace conventional systems, which operate at faster speeds. KUKA also identifies high payload, maximum speed and demanding manufacturing capability as reasons to consider a conventional system (IFR; KUKA’s cobot-versus-robot comparison).
Do these 3 things before closing this tab:
1Scan for outdated or missing drivers - takes under a minute2Repair Windows errors before they cause bigger problems3Fix the driver behind crashes, sound loss and screen glitchesA cobot may suit a task where workers contribute alongside automation, batches are small, products change often, or reprogramming and redeployment are valuable. That flexibility is not a guarantee of a lower project cost, faster installation or adequate production rate. Validate it against the required output and the whole application.
Compare the actual candidates
| Decision factor | Cobot application | Conventional industrial robot cell |
|---|---|---|
| Cycle time and sustained output | Check whether the required rate is achievable for the task and safety setup; do not infer it from the cobot label. | Often the stronger candidate when high speed and throughput dominate. |
| Payload and reach | Compare model specifications with the complete load, including the tool and workpiece, at the required reach. | Consider when payload or reach requirements exceed suitable cobot candidates. |
| Product variation and changeovers | Potentially useful when frequent reprogramming or redeployment matters. | May suit stable, repeatable processes with a dedicated setup. |
| People working nearby | Designed for collaborative applications, but the complete task still needs risk assessment and may need safeguards. | Cell layout and safeguards must be designed for the application’s risks and operating conditions. |
| Footprint, integration and project economics | Assess the full application, including tooling, integration and safeguards; a cobot does not establish a lower installed cost. | Assess the full cell and its integration scope; no universal cost or payback advantage is established for either option. |
These are screening considerations, not model specifications. Compare vendor performance at the relevant payload and motion conditions. KUKA lists payload, reach, cycle time, safety requirements, footprint and ROI among selection criteria (KUKA).
Rank #2
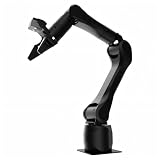
- Synria Alicia-M is a lightweight 6-axis robotic arm designed for embodied AI research, robotics laboratories, teleoperation, imitation learning, and light industrial automation. It supports advanced manipulation workflows for VLA, ACT, and Diffusion Policy applications.
- With a 750mm working space and 1.5kg continuous effective payload, Alicia-M provides a larger operating range for object handling, testing, teaching, and automation tasks while maintaining a compact desktop-friendly structure.
- Built with precision motion control, Alicia-M offers ±0.1mm repeatability to support reliable task execution, experimental consistency, and long-term robotic operation in research, education, and engineering environments.
- Supports ROS2 teleoperation, gravity compensation, velocity mode, and MIT force control mode, enabling smoother manual guidance, responsive control, and safer interaction during data collection, task demonstration, and robotic learning.
- The full machine weighs approximately 5.1kg and uses DC24V power with CAN communication, making it easier to deploy in labs, classrooms, R&D workstations, and light industrial scenarios. Compatible with open-source robotics workflows and simulation-first control development.
How should you compare costs and return?
Do not select on purchase price alone. Installed cost and payback depend on the complete application, and the available sources do not establish comparable factory-specific prices or ROI figures. Ask integrators to price the same production requirement and safety scope so the proposals can be compared on equal terms.
- Include the robot and controller, end effector, fixtures, tooling, integration, programming, commissioning and any required safeguards.
- Estimate output using the required cycle time and sustained production schedule, not a headline robot speed detached from the task.
- Account for changeovers, maintenance capability, downtime and the work operators still perform.
- Compare the proposed floor-space and cell requirements alongside capital and operating costs.
These factors align with KUKA’s stated selection criteria and ISO 10218-2:2025’s scope for integrating and commissioning robot applications and cells (KUKA; ISO 10218-2:2025).
The Tool Desk
Outbyte Driver Updater FREEFix the driver behind crashes, sound loss and screen glitchesFind Drivers →Outbyte PC Repair FREEClear out junk files and repair common Windows errorsFree Scan →Do collaborative robots need safety fencing?
Not automatically, and not never. A collaborative label does not prove that a complete application is safe to run beside workers or that guarding is unnecessary. Risk depends on the robot together with its end effector, workpiece, speed, task, layout and foreseeable human interaction. The appropriate safeguards follow from assessment of the application, not the product name.
The current 2025 editions of ISO 10218 separate requirements for the robot as a machine from requirements for integrating it into an application or cell. ISO 10218-1:2025 covers the robot; ISO 10218-2:2025 covers integration, commissioning, operation, maintenance and decommissioning of applications and cells (ISO 10218-1:2025; ISO 10218-2:2025). ISO/TS 15066:2016 supplements ISO 10218 guidance for collaborative industrial robot systems and work environments; ISO reports it was confirmed in 2022 and remains current, with revision underway (ISO/TS 15066 status and scope).
Rank #4
- Synria Alicia-M is a lightweight 6-axis robotic arm designed for embodied AI research, robotics laboratories, teleoperation, imitation learning, and light industrial automation. It supports advanced manipulation workflows for VLA, ACT, and Diffusion Policy applications.
- With a 750mm working space and 1.5kg continuous effective payload, Alicia-M provides a larger operating range for object handling, testing, teaching, and automation tasks while maintaining a compact desktop-friendly structure.
- Built with precision motion control, Alicia-M offers ±0.1mm repeatability to support reliable task execution, experimental consistency, and long-term robotic operation in research, education, and engineering environments.
- Supports ROS2 teleoperation, gravity compensation, velocity mode, and MIT force control mode, enabling smoother manual guidance, responsive control, and safer interaction during data collection, task demonstration, and robotic learning.
- The full machine weighs approximately 5.1kg and uses DC24V power with CAN communication, making it easier to deploy in labs, classrooms, R&D workstations, and light industrial scenarios. Compatible with open-source robotics workflows and simulation-first control development.
The 2011 editions of ISO 10218-1 and -2 have been withdrawn and replaced by the 2025 editions. Apply the standards and local requirements relevant to your installation, and have a qualified safety professional assess the application; this overview is not an engineering specification or risk assessment.
Independent reader supportYour contribution helps us test, update, and keep practical guides available for everyone.What the market statistic does—and does not—tell you
IFR reported that collaborative robots accounted for 10.5% of 541,302 industrial robots installed in 2023, in the context of its World Robotics 2024 data. IFR describes cobots as complementary to conventional industrial robots, rather than replacements for faster systems used to improve productivity under tight product margins (IFR’s report context and statement). This is a historical installation figure, not a current-year estimate or evidence that either type is right for a particular factory.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Best Value

- Cobots represent a distinct class of automated industrial mechanisms integrated with specialized spatial awareness architecture. The core mechanics of cobots utilize high-fidelity torque sensors and limiters at every single articulation joint.
- Cobots utilize specific physical collision mitigation algorithms to operate inside unsegregated workspaces. Unlike traditional machinery, the programming framework of cobots permits simultaneous operational proximity to human operators.
- Lightweight, Classic fit, Double-needle sleeve and bottom hem
A practical selection checklist
- Write down the task, workpiece, required output, cycle time and production schedule.
- Set payload and reach requirements, including the end effector and workpiece, and specify the mounting and workspace.
- Document precision and repeatability needs as defined by the process, along with task variation and changeover frequency.
- Decide how people will interact with the process and include the intended safeguards and safety-assessment scope.
- Assess footprint, programming and maintenance resources, tooling, integration and commissioning.
- Request proposals for the same requirements and scope, then compare total project economics rather than robot purchase prices alone.
Model-level specifications and the factory process determine whether a candidate can meet these requirements. Have an integrator validate cycle performance and system scope before treating a product-class comparison as a purchasing decision.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.




